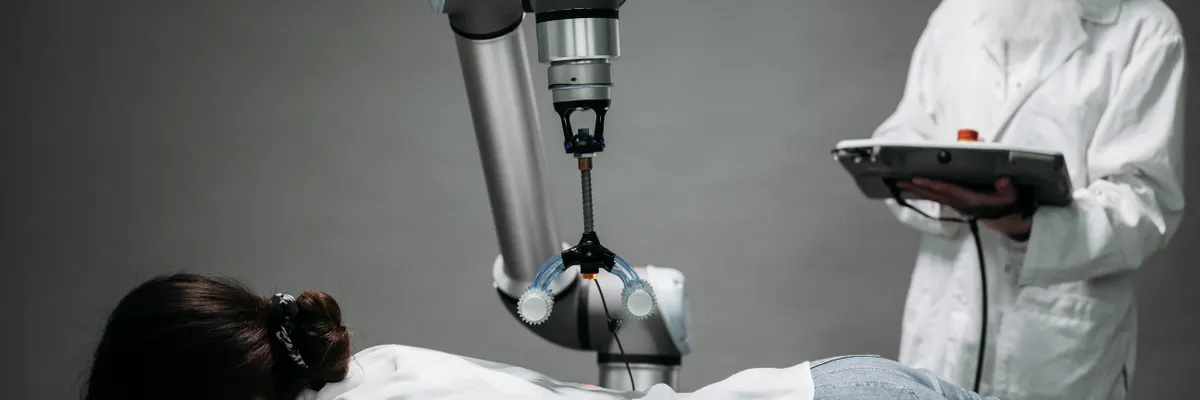
Training robots for the operating room is a brutal data problem. Real-world surgical data is scarce, expensive, and ethically thorny. Nvidia’s answer with the new Isaac for Healthcare v0.4 framework is to mostly ignore the real world—at least at first. Their new SO-ARM starter workflow leans heavily on simulation, using synthetic data for over 93% of the policy training for a surgical assistant robot. That’s not a typo. Only a handful of real-world demonstrations are needed to ground the model, which is a wild departure from the old-school approach of endless physical trial and error.
The secret sauce is a sim-to-real mixed training approach that doesn’t treat simulation as a crutch but as the primary engine. Developers can generate roughly 70 simulated episodes full of diverse scenarios and environmental noise, then blend in 10 to 20 real-world teleoperation episodes for authenticity. The result is a policy trained on the post-trained GR00T N1.5 model that generalizes far better than one trained in a single domain. Isaac Lab handles the evaluation and RTI DDS handles the real-time communication on the physical SO-ARM101 hardware, a 6-DOF precision manipulator kitted out with a wrist-mounted camera.
What makes this more than just another robotics framework is the barrier it lowers. The entire pipeline—data collection with LeRobot, simulation-based policy training, and final deployment on hardware—can run on a single DGX Spark computer. For MedTech developers who’ve been locked out of robotics by hardware costs and data scarcity, that’s a major shift. It turns months of prototyping into days, letting them build and validate autonomous workflows in a virtual operating room before a robot ever picks up a scalpel. Nvidia isn’t just selling shovels for the AI gold rush; they’re giving away the blueprint for a whole new kind of mine.